

Basic and Generic Governors
This page documents the four governors built into every RAMSES distribution, CONSTANT, 1ST_ORDER, HYDRO_GENERIC1 and THERMAL_GENERIC1, which take no prefix and are written in uppercase, together with HYDRO_DG, registered since 3.76.
The TOR sub-record these models are entered with is described on the Governor Models page.
CONSTANT (tor_constant)
Section titled “CONSTANT (tor_constant)”The data-file model name is CONSTANT.
Scientific Description
Section titled “Scientific Description”The tor_constant model provides a constant mechanical torque source. The mechanical torque is fixed at its initialisation value and does not respond to speed deviations or load changes:
The single algebraic state satisfies:
The observable output is mechanical power:
Implementation details:
nbxvar = 1,nbzvar = 0,nbdata = 0- One additional parameter:
prm(1) = Tm0(set at initialisation from load-flow) - Observable:
Pm = x(1) * omega
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
| (none) | No user-supplied parameters. is taken from the load-flow initialisation. |
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g6 g6 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 400. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 360. # H: Inertia constant (s) 6. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 2.05 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 2.2 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.3 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 2. # X'q: q-axis transient reactance (pu) 0.4 # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 7.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) 1.5 # T"qo: q-axis open-circuit subtransient time constant (s) 0.05EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 3.0618 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 1. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 0. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -20.0 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 120. # TA: AVR lead time constant (s) 5. # TB: AVR lag time constant (s) 12.5 # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 5. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.22 # T2: PSS first lead-lag denominator time constant (s) 0.012 # T3: PSS second lead-lag numerator time constant (s) 0.22 # T4: PSS second lead-lag denominator time constant (s) 0.012 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR CONSTANT;- Useful for machines operating at fixed setpoint, for testing generator models in isolation, or as a placeholder.
- The mechanical power observable will vary slightly with speed changes.
TOR CONSTANTtakes no parameters, is set automatically from the load-flow initialisation.
1ST_ORDER (tor_1storder)
Section titled “1ST_ORDER (tor_1storder)”The data-file model name is 1ST_ORDER (uppercase, with the underscore).
Scientific Description
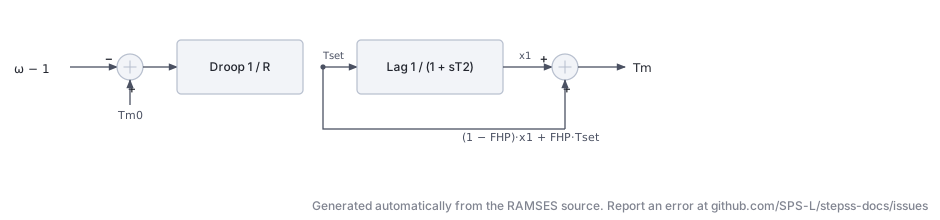
Section titled “Scientific Description”The tor_1storder model is a first-order speed governor with droop and a two-mass (HP/LP) turbine representation. It captures the primary frequency response through a proportional-droop speed controller with a first-order lag.
Speed controller with droop :
The mechanical torque setpoint is:
The HP torque tracks through a first-order lag with time constant :
The LP (shaft) torque is a weighted combination:
where is the fraction of power generated in the HP stage.
From the Fortran equations:
f(1) = (-x(1) + (prm(4) - (omega-1.d0)/prm(3))) / prm(2)f(2) = (1.d0-prm(1))*x(1) + prm(1)*(prm(4)-(omega-1.d0)/prm(3)) - x(2)i.e.:
prm(1) = FHP(HP fraction),prm(2) = T2(time constant),prm(3) = R(droop)prm(4) = Tm0(setpoint, set at init)
Implementation details:
nbxvar = 2,nbzvar = 0,nbdata = 3- State 1 = HP torque
x(1), State 2 = LP torquex(2) - Observables:
HP torque,LP torque
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
FHP | Fraction of torque produced by the HP turbine stage (0–1) |
T2 | Governor/HP turbine time constant (s) |
R | Speed droop (pu/pu) |
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 800. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 760. # H: Inertia constant (s) 3. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 0.95 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 1.1 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.25 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 0.7 # X'q: q-axis transient reactance (pu) * # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 5.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) * # T"qo: q-axis open-circuit subtransient time constant (s) 0.1EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 1.8991 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 0. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 1. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -11 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 70. # TA: AVR lead time constant (s) 10. # TB: AVR lag time constant (s) 20. # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 4. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.2 # T2: PSS first lead-lag denominator time constant (s) 0.01 # T3: PSS second lead-lag numerator time constant (s) 0.2 # T4: PSS second lead-lag denominator time constant (s) 0.01 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR 1ST_ORDER # FHP: fraction of torque following the setpoint without lag (HP part) 0.30 # T2: time constant of the lagged (LP) torque part (s) 0.50 # R: speed droop (pu) 0.05;FHP = 0makes the model a pure first-order lag on the total torque.FHP = 1bypasses the HP lag entirely; the torque instantly tracks the droop setpoint.- Typical primary-frequency response studies use
R = 0.04–0.05.
THERMAL_GENERIC1 (tor_thermal_generic1)
Section titled “THERMAL_GENERIC1 (tor_thermal_generic1)”The data-file model name is THERMAL_GENERIC1.
Scientific Description
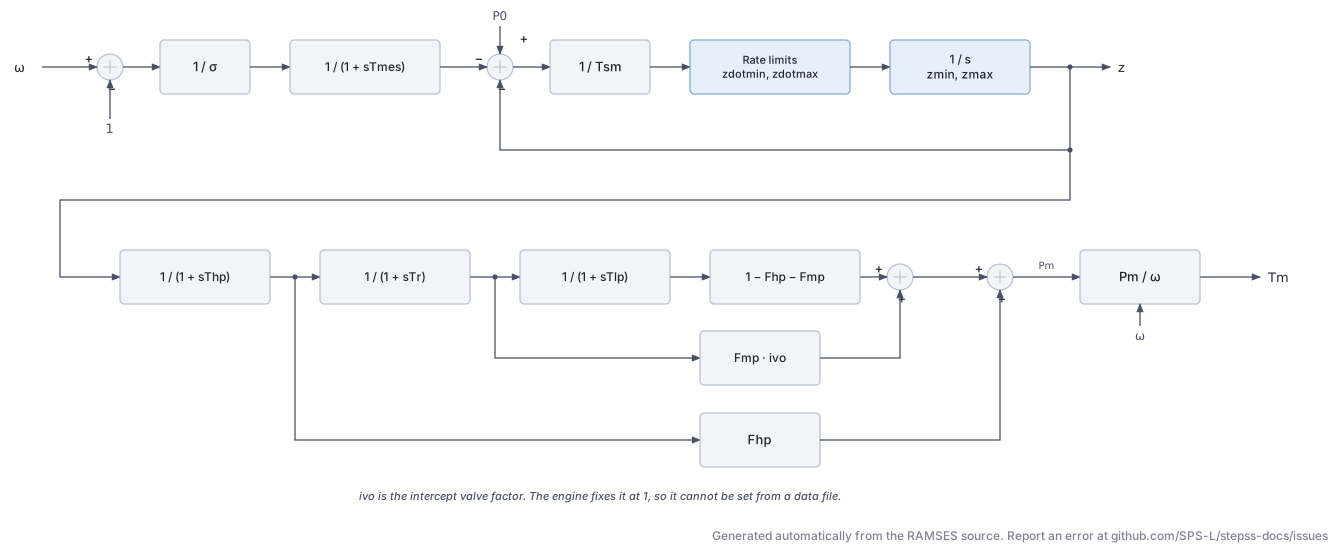
Section titled “Scientific Description”The tor_thermal_generic1 model is a generic multi-stage steam turbine governor, suitable for both single-shaft and cross-compound units. It includes a speed controller with rate-limiting, a three-section steam chest/reheater, and separate HP, MP, and LP turbine stages.
Speed governor:
The speed deviation is divided by the droop and measured with time constant :
The gate demand is what remains of the power setpoint after that term and the current gate position are taken off:
It is divided by the servo time constant , rate-limited to , and integrated into the gate opening within .
Turbine power stages:
The gate opening drives three lags in series, the reheat stage carrying the intercept valve factor :
Each stage contributes its own fraction of the power, and the three fractions sum to one:
Total mechanical power, and the torque delivered to the shaft:
Parameters:
| Parameter | Index | Description |
|---|---|---|
sigma | 1 | Speed droop (pu/pu) |
Tmes | 2 | Speed measurement time constant (s) |
Tsm | 3 | Servo/gate time constant (s) |
zdotmin | 4 | Minimum gate rate (pu/s) |
zdotmax | 5 | Maximum gate rate (pu/s) |
zmin | 6 | Minimum gate opening (pu) |
zmax | 7 | Maximum gate opening (pu) |
Thp | 8 | HP turbine time constant (s) |
Fhp | 9 | HP power fraction |
Tr | 10 | Reheater / MP time constant (s) |
Fmp | 11 | MP power fraction |
Tlp | 12 | LP turbine time constant (s) |
Implementation details:
nbxvar = 10,nbzvar = 2,nbdata = 12,nbaddpar = 2- Additional:
prm(13) = P0(initial power),prm(14) = ivo(intercept valve factor)
- Observables:
z,PmHP,PmMP,PmLP,Pm
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 800. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 760. # H: Inertia constant (s) 3. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 0.95 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 1.1 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.25 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 0.7 # X'q: q-axis transient reactance (pu) * # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 5.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) * # T"qo: q-axis open-circuit subtransient time constant (s) 0.1EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 1.8991 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 0. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 1. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -11 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 70. # TA: AVR lead time constant (s) 10. # TB: AVR lag time constant (s) 20. # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 4. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.2 # T2: PSS first lead-lag denominator time constant (s) 0.01 # T3: PSS second lead-lag numerator time constant (s) 0.2 # T4: PSS second lead-lag denominator time constant (s) 0.01 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR THERMAL_GENERIC1 # sigma: speed droop (pu) 0.05 # Tmes: speed measurement time constant (0 = no lag) (s) 0.02 # Tsm: valve servomotor time constant (s) 0.20 # zdotmin: minimum valve rate, applied as given so normally negative (pu/s) -0.10 # zdotmax: maximum valve rate (pu/s) 0.10 # zmin: minimum valve position (pu) 0.0 # zmax: maximum valve position (pu) 1.05 # Thp: HP steam chest time constant (0 = no lag) (s) 0.30 # Fhp: HP power fraction 0.30 # Tr: reheater time constant (0 = no lag) (s) 7.0 # Fmp: MP power fraction 0.40 # Tlp: LP stage time constant (0 = no lag) (s) 0.50;- The LP fraction is
1 - Fhp - Fmp; ensureFhp + Fmp ≤ 1. - Set
Tmes = 0to bypass the speed measurement filter (instantaneous speed sensing). - Rate limits
zdotmin/zdotmaxare critical for AGC studies.
HYDRO_GENERIC1 (tor_hydro_generic1)
Section titled “HYDRO_GENERIC1 (tor_hydro_generic1)”The data-file model name is HYDRO_GENERIC1.
Scientific Description
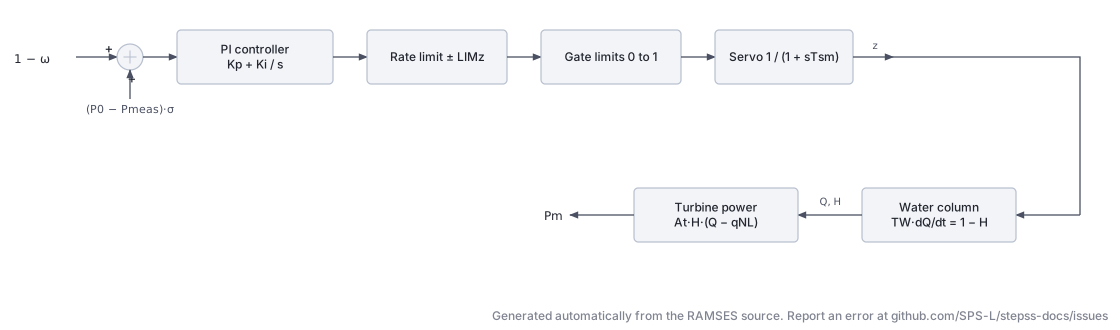
Section titled “Scientific Description”The tor_hydro_generic1 model is a generic hydraulic turbine governor with a penstock (water column) and PI controller. It implements the standard hydraulic governor structure following IEEE Std 1110 conventions.
PI speed governor:
The speed error with droop :
A PI controller with gains and drives the gate demand:
The gate is rate-limited by and position-limited by , with a servo time constant .
Water column (penstock):
The flow and head are related by the water-starting time :
The head is:
where is the no-load flow fraction.
Turbine mechanical torque:
Parameters:
| Parameter | Index | Description |
|---|---|---|
SIGMA | 1 | Speed droop (pu/pu) |
Tmes | 2 | Speed measurement time constant (s) |
Qv | 3 | No-load water flow fraction (pu) |
KP | 4 | PI proportional gain |
KI | 5 | PI integral gain |
TSM | 6 | Gate servo time constant (s) |
LIMZDOT | 7 | Gate velocity limit (pu/s) |
TW | 8 | Water starting time (s) |
Implementation details:
nbxvar = 6,nbzvar = 2,nbdata = 8,nbaddpar = 1- Additional:
prm(9) = P0(initial electrical power) - Observables:
z,Q,H,Pm
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 800. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 760. # H: Inertia constant (s) 3. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 0.95 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 1.1 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.25 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 0.7 # X'q: q-axis transient reactance (pu) * # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 5.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) * # T"qo: q-axis open-circuit subtransient time constant (s) 0.1EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 1.8991 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 0. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 1. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -11 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 70. # TA: AVR lead time constant (s) 10. # TB: AVR lag time constant (s) 20. # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 4. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.2 # T2: PSS first lead-lag denominator time constant (s) 0.01 # T3: PSS second lead-lag numerator time constant (s) 0.2 # T4: PSS second lead-lag denominator time constant (s) 0.01 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR HYDRO_GENERIC1 # SIGMA: permanent droop, gain on the power error P0 minus measured P (pu) 0.04 # Tmes: electrical power measurement time constant (s) 2.0 # Qv: no-load water flow (pu) 0. # KP: PI proportional gain 2.00 # KI: PI integral gain (1/s) 0.40 # TSM: gate servomotor time constant (s) 0.2 # LIMZDOT: gate velocity limit, applied as plus or minus (pu/s) 0.1 # TW: water starting time (s) 1.0;TW(water-starting time) is the most influential parameter; typical values are 0.5–3 s.- Increase
KP/KIcarefully: large values can cause governor instability with highTW. Qv = 0assumes no no-load losses.- Parameters follow the order in
dyn_A.txt:SIGMA TP Qv KP KI TSM LIMZDOT TW.
HYDRO_DG (tor_HYDRO_DG)
Section titled “HYDRO_DG (tor_HYDRO_DG)”The data-file model name is HYDRO_DG. Registered since 3.76.
Scientific Description
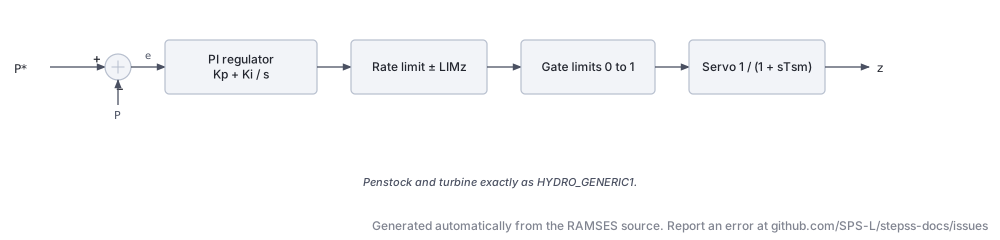
Section titled “Scientific Description”A hydraulic turbine governor for a dispersed generation unit that holds an active-power setpoint and does not provide primary frequency response.
The penstock and turbine are exactly those of HYDRO_GENERIC1.
What differs is the governor control law, and the difference is the point of the model.
HYDRO_GENERIC1 is a speed governor: its error signal carries an unconditional frequency
term, so the unit responds to system frequency whether or not that is wanted. HYDRO_DG
regulates power alone.
PI power regulator:
The error is the deviation from the setpoint captured at initialisation, with no droop term and no speed term:
There is no measurement lag on , so the regulator acts on the instantaneous electrical power. The gate follows through a servo of time constant , rate-limited to and position-limited to .
Water column and turbine, identical to HYDRO_GENERIC1:
Parameters:
| Parameter | Index | Description |
|---|---|---|
Qv | 1 | No-load water flow fraction (pu) |
Kp | 2 | PI proportional gain |
Ki | 3 | PI integral gain |
TSM | 4 | Gate servo time constant (s) |
LIMZDOT | 5 | Gate velocity limit (pu/s) |
TW | 6 | Water starting time (s) |
These are exactly parameters 3 to 8 of HYDRO_GENERIC1, in the same order. HYDRO_GENERIC1
precedes them with SIGMA (droop) and Tmes (speed measurement lag), and those two are what
HYDRO_DG does not have. Setting SIGMA to zero in HYDRO_GENERIC1 does not reproduce
HYDRO_DG, because the frequency term survives.
Implementation details:
nbxvar = 5,nbzvar = 2,nbdata = 6,nbaddpar = 1- Additional:
prm(7) = Pset, the initial electrical power, captured at initialisation - Observables:
z,Q,H,Pm,Pset
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH G4 N4 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 5 # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 4.5 # H: Inertia constant (s) 3. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 1.9333 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.0937 # Xd: d-axis synchronous reactance (pu) 2.027 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.210 # X"d: d-axis subtransient reactance (pu) 0.173 # Xq: q-axis synchronous reactance (pu) 2.027 # X'q: q-axis transient reactance (pu) * # X"q: q-axis subtransient reactance (pu) 0.173 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6 # Ra: Armature resistance (pu) 0.00 # T'do: d-axis open-circuit transient time constant (s) 3.1 # T"do: d-axis open-circuit subtransient time constant (s) 0.0387 # T'qo: q-axis open-circuit transient time constant (s) * # T"qo: q-axis open-circuit subtransient time constant (s) 0.0387EXC AVR_DG # IFLIM: OEL field current threshold (pu) 2.865 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 0. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 1. # K1: Not used by the code 100. # K2: OEL gain on field current error if minus IFLIM (pu/pu) -1. # L1: OEL timer lower limit (initial value) (s) -20 # L2: OEL timer upper limit (s) 10 # G: AVR gain (pu/pu) 50 # TA: AVR lead time constant (s) 4 # TB: AVR lag time constant (s) 20 # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0 # L4: Maximum field voltage (pu) 5 # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 0. # Tw: PSS washout time constant (s) 5. # T1: PSS first lead-lag numerator time constant (s) 1. # T2: PSS first lead-lag denominator time constant (s) 1. # T3: PSS second lead-lag numerator time constant (s) 1. # T4: PSS second lead-lag denominator time constant (s) 1. # DVMIN: PSS output lower limit (pu) 0. # DVMAX: PSS output upper limit (pu) 0. # KQP: Reactive power regulator proportional gain (pu/pu) 0.04 # KQI: Reactive power regulator integral gain (1/s) 0.06 # L5: Reactive power regulator output lower limit (pu) -0.2 # L6: Reactive power regulator output upper limit (pu) 0.33TOR HYDRO_DG # Qv: no-load water flow (pu) 0.0 # Kp: PI proportional gain on power error 0.1 # Ki: PI integral gain on power error (1/s) 0.4 # TSM: gate servomotor time constant (s) 0.2 # LIMZDOT: gate velocity limit, applied as plus or minus (pu/s) 0.1 # TW: water starting time (s) 1.0;- The setpoint is not a parameter.
Psetis captured from the power-flow solution at initialisation, so the unit holds whatever it was dispatched to. - Because there is no frequency term, a system built only of these units has no primary frequency control. That is deliberate for dispersed generation studies, and it is worth being explicit about when interpreting a frequency response.
Qv = 0assumes no no-load losses.- The head relation divides by the gate position, which is floored at 1e-3 in the implementation so a fully closed gate cannot produce a division by zero.