

IEEE Governors
This page documents the IEEE-standard turbine-governor models available in RAMSES, all using the tor_ prefix. These models implement standardised transfer-function blocks for diesel, gas-turbine, steam-turbine, hydraulic, and simplified ENTSO-E governors.
The TOR sub-record these models are entered with is described on the Governor Models page.
DEGOV1 (tor_DEGOV1)
Section titled “DEGOV1 (tor_DEGOV1)”Scientific Description
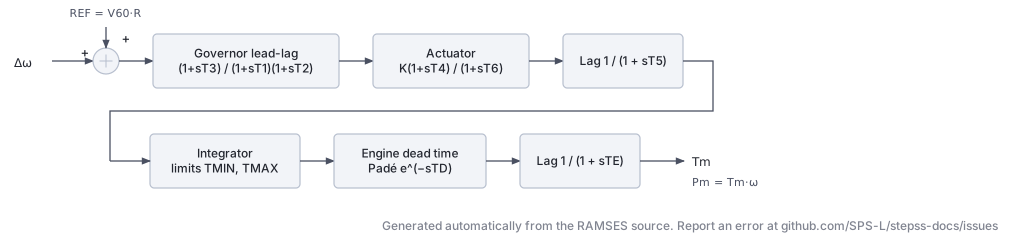
Section titled “Scientific Description”The DEGOV1 model represents the diesel engine governor as defined in the IEEE Committee Report on governors. It consists of three main stages:
1. Speed governor (electrical control / lead–lag)
The speed error is formed from the measured speed deviation and a reference signal derived from either mechanical power () or mechanical torque (), selected by the switch :
The governor speed error drives a second-order lead–lag controller (transfer function approximating a two-pole, two-zero system) with time constants , , :
2. Actuator (fuel injection system)
The governor output passes through a lead–lag block with gain and time constants , :
followed by a first-order lag , and an integrator with limits .
3. Engine dead time and torque output
The actuator output is subject to engine dead time , approximated by a second-order Padé:
The final mechanical torque is computed as:
The droop characteristic is:
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
SWM | Input switch: 0 = mechanical torque (), 1 = electrical power () |
T1 | Governor time constant, lead numerator (s) |
T2 | Governor time constant, lag denominator (s) |
T3 | Governor time constant, second-order denominator (s) |
K | Actuator gain |
T4 | Actuator lead time constant (s) |
T5 | First-order actuator lag (s) |
T6 | Actuator lag time constant (s) |
TMIN | Minimum fuel/torque limit (pu) |
TMAX | Maximum fuel/torque limit (pu) |
TD | Engine dead time (s) |
R | Speed droop (pu/pu) |
TE | Engine time constant (s) |
Internal parameters: V60 (selected reference input, mechanical torque or electrical power according to SWM) and REF (V60 · R), both set at initialisation
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 600. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 570. # H: Inertia constant (s) 6. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 2.05 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 2.2 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.3 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 2. # X'q: q-axis transient reactance (pu) 0.4 # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 7.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) 1.5 # T"qo: q-axis open-circuit subtransient time constant (s) 0.05EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 3.0618 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 1. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 0. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -20.0 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 120. # TA: AVR lead time constant (s) 5. # TB: AVR lag time constant (s) 12.5 # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 5. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.22 # T2: PSS first lead-lag denominator time constant (s) 0.012 # T3: PSS second lead-lag numerator time constant (s) 0.22 # T4: PSS second lead-lag denominator time constant (s) 0.012 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR DEGOV1 # SWM: droop feedback switch, 0 = actuator output, 1 = electrical power 0 # T1: control box denominator time constant (s term) (s) 0.02 # T2: control box second time constant, s2 coefficient T1*T2; ignored if T1*T2 < 0.005 (s) 0.02 # T3: control box lead time constant (s) 0.20 # K: actuator gain; the actuator is K(1+sT4)/(s(1+sT5)(1+sT6)) (1/s) 1.0 # T4: actuator lead time constant (s) 0.25 # T5: actuator lag time constant (s) 0.009 # T6: actuator lead-lag denominator time constant (s) 0.038 # TMIN: minimum actuator output (pu) 0.0 # TMAX: maximum actuator output (pu) 1.05 # TD: engine dead time, Pade approximation; second order only if TD >= 0.245 s (s) 0.01 # R: speed droop (pu) 0.05 # TE: electrical power measurement time constant (s) 0.05;- Set
SWM = 0to use mechanical torque as the reference input,SWM = 1for electrical power. TMINandTMAXare per-unit limits on the integrator output (fuel demand / valve position).Ris the permanent droop; typical values are 0.04–0.05 pu/pu.- The Padé approximation of the dead time is a second-order filter.
- Parameters are listed in order:
SWM T1 T2 T3 K T4 T5 T6 TMIN TMAX TD R TE.
ENTSOE_simp (tor_ENTSOE_simp)
Section titled “ENTSOE_simp (tor_ENTSOE_simp)”Scientific Description
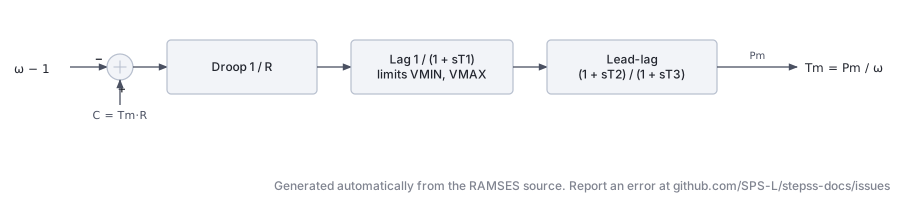
Section titled “Scientific Description”The ENTSOE_simp model is a simplified ENTSO-E speed governor suitable for primary frequency response studies. It is derived from the ENTSO-E recommendations for equivalent turbine-governor representation.
The governor equation forms a speed error with permanent droop :
This error drives a first-order lag (representing the valve or steam chest) with limits :
The turbine mechanical power is modelled by a lead–lag transfer function with time constants (zero) and (pole):
The final mechanical torque output accounting for shaft speed is:
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
R | Permanent speed droop (pu/pu) |
T1 | Governor/valve time constant (s) |
VMIN | Minimum valve position / lower output limit (pu) |
VMAX | Maximum valve position / upper output limit (pu) |
T2 | Turbine lead time constant, zero (s) |
T3 | Turbine lag time constant, pole (s) |
Internal parameter: C = Tm · R (initialised from the load-flow mechanical torque)
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 400. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 360. # H: Inertia constant (s) 6. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 2.05 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 2.2 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.3 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 2. # X'q: q-axis transient reactance (pu) 0.4 # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 7.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) 1.5 # T"qo: q-axis open-circuit subtransient time constant (s) 0.05EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 3.0618 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 1. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 0. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -20.0 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 120. # TA: AVR lead time constant (s) 5. # TB: AVR lag time constant (s) 12.5 # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 5. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.22 # T2: PSS first lead-lag denominator time constant (s) 0.012 # T3: PSS second lead-lag numerator time constant (s) 0.22 # T4: PSS second lead-lag denominator time constant (s) 0.012 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR ENTSOE_simp # R: permanent speed droop (pu) 0.05 # T1: governor valve time constant (s) 0.50 # VMIN: minimum valve position (pu) 0.0 # VMAX: maximum valve position (pu) 1.1 # T2: turbine lead time constant (s) 0.0 # T3: turbine lag time constant (s) 10.0;- Typical primary-frequency response studies use –.
- Setting simplifies the turbine to a pure first-order lag .
- This model is commonly used as a simplified equivalent for aggregated generation.
- Parameters are listed in order:
R T1 VMIN VMAX T2 T3.
GAST (tor_GAST)
Section titled “GAST (tor_GAST)”Scientific Description
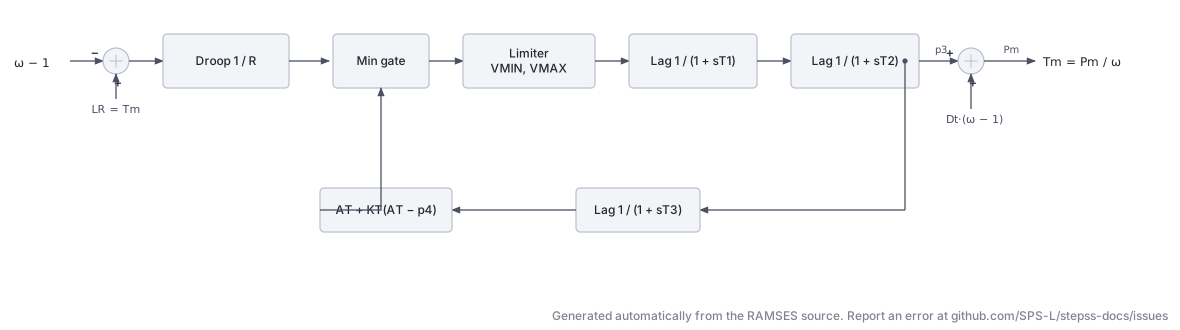
Section titled “Scientific Description”The GAST model represents a gas turbine unit, following the IEEE Committee Report (1973) and the convention common to industry tools. It captures the speed governor, compressor discharge lag, and fuel/combustion dynamics.
Speed governor with droop and load reference:
where (load reference, initialised from mechanical torque) and is the droop.
The speed error drives a value position through a limiter and a first-order lag :
The compressor discharge is modelled by lag :
The mechanical power (including speed-dependent damping ) is:
The exhaust temperature is tracked by a lag :
A temperature limit is applied via:
A minimum gate blocks the valve position: .
The torque-power conversion:
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
R | Permanent speed droop (pu/pu) |
T1 | Governor/valve time constant (s) |
T2 | Compressor discharge time constant (s) |
T3 | Radiation shield / exhaust temperature lag (s) |
AT | Ambient temperature load limit (pu) |
KT | Temperature control loop gain |
VMAX | Maximum valve position (pu) |
VMIN | Minimum valve position (pu) |
DTURB | Turbine damping factor (pu torque / pu speed) |
Internal parameter: LR = Tm (load reference, set at initialisation)
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 400. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 360. # H: Inertia constant (s) 6. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 2.05 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 2.2 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.3 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 2. # X'q: q-axis transient reactance (pu) 0.4 # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 7.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) 1.5 # T"qo: q-axis open-circuit subtransient time constant (s) 0.05EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 3.0618 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 1. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 0. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -20.0 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 120. # TA: AVR lead time constant (s) 5. # TB: AVR lag time constant (s) 12.5 # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 5. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.22 # T2: PSS first lead-lag denominator time constant (s) 0.012 # T3: PSS second lead-lag numerator time constant (s) 0.22 # T4: PSS second lead-lag denominator time constant (s) 0.012 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR GAST # R: permanent speed droop (pu) 0.05 # T1: fuel valve time constant (s) 0.40 # T2: fuel system time constant (s) 0.10 # T3: load limit (exhaust temperature) time constant (s) 3.00 # AT: ambient temperature load limit (pu) 1.00 # KT: temperature limiter gain 2.50 # VMAX: maximum valve position (pu) 1.05 # VMIN: minimum valve position (pu) 0.0 # DTURB: turbine damping (pu) 0.0;- Based on the IEEE Committee Report on “Dynamic Models for Steam and Hydro Turbines in Power System Studies” (1973), later adapted for gas turbines.
ATandKTdefine the exhaust-temperature protection characteristic.DTURB = 0disables speed-dependent damping.- Parameters are listed in order:
R T1 T2 T3 AT KT VMAX VMIN DTURB.
TGOV1 (tor_TGOV1D)
Section titled “TGOV1 (tor_TGOV1D)”Scientific Description
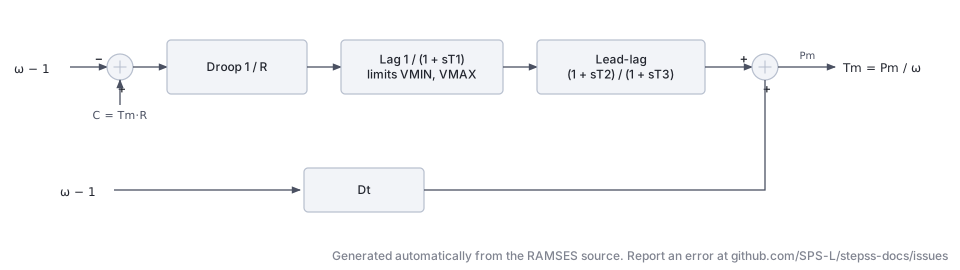
Section titled “Scientific Description”The TGOV1 model represents a simple steam turbine governor, based on the IEEE TGOV1 structure with an added damping term. It is one of the most widely used simple governor models in power-system stability studies.
Speed governor with permanent droop:
The speed error (with droop ) drives a first-order lag with output limits :
Turbine with reheater and damping:
The valve position passes through a lead–lag block representing the steam chest and reheater:
The total mechanical power includes a speed-dependent damping term :
Hence the mechanical torque:
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
R | Permanent speed droop (pu/pu) |
T1 | Steam chest / valve actuator time constant (s) |
VMAX | Maximum valve position (pu) |
VMIN | Minimum valve position (pu) |
T2 | Lead time constant, reheater zero (s) |
T3 | Lag time constant, reheater pole (s) |
Dt | Turbine damping coefficient (pu torque / pu speed deviation) |
Internal parameter: C = Tm · R (initialised from load-flow mechanical torque)
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 400. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 360. # H: Inertia constant (s) 6. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 2.05 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 2.2 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.3 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 2. # X'q: q-axis transient reactance (pu) 0.4 # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 7.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) 1.5 # T"qo: q-axis open-circuit subtransient time constant (s) 0.05EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 3.0618 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 1. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 0. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -20.0 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 120. # TA: AVR lead time constant (s) 5. # TB: AVR lag time constant (s) 12.5 # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 5. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.22 # T2: PSS first lead-lag denominator time constant (s) 0.012 # T3: PSS second lead-lag numerator time constant (s) 0.22 # T4: PSS second lead-lag denominator time constant (s) 0.012 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR TGOV1 # R: permanent speed droop (pu) 0.05 # T1: steam valve time constant (s) 0.50 # VMAX: maximum valve position (pu) 1.05 # VMIN: minimum valve position (pu) 0.0 # T2: reheater lead time constant (s) 2.10 # T3: reheater lag time constant (s) 7.00 # Dt: turbine damping (pu) 0.0;- This is essentially the IEEE TGOV1 model with an additional damping term .
- Setting gives a pure first-order turbine .
- adds a stabilising speed-dependent power correction (useful for islanded operation).
- Parameters are listed in order:
R T1 VMAX VMIN T2 T3 Dt.
HYGOV (tor_hygov)
Section titled “HYGOV (tor_hygov)”Scientific Description
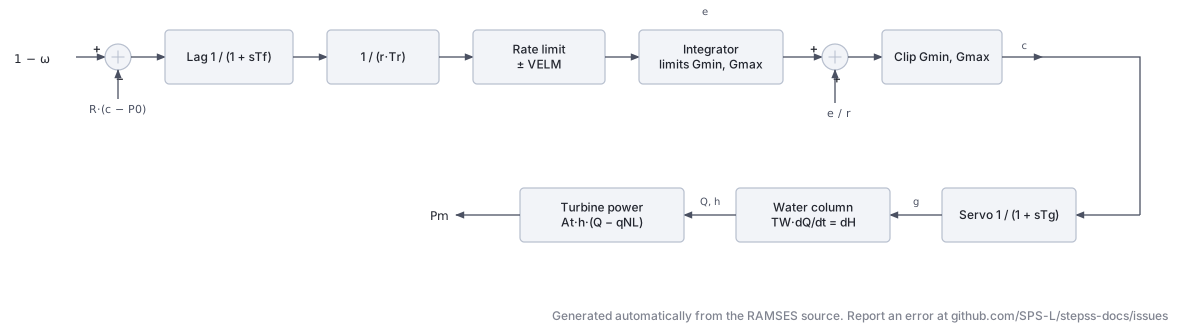
Section titled “Scientific Description”The HYGOV model represents a hydraulic turbine and governor following a simplified penstock/water-column formulation, consistent with the IEEE representation for hydro governors (IEEE Std 1110).
Governor with droop and PI controller:
The speed error (with permanent droop and transient droop ) enters a lag to produce the error signal :
The rate of change of gate demand is computed via the transient droop:
This is rate-limited to , then integrated with gate limits :
The PI controller output (desired gate) is:
The actual gate position follows through the servo:
Penstock / water column:
The head deviation is determined by the non-linear water flow equation and water-starting time :
Turbine mechanical torque:
Parameters
Section titled “Parameters”| Parameter | Description |
|---|---|
R | Permanent droop (pu/pu) |
r | Transient droop (pu/pu) |
Tr | Transient droop reset time (s) |
Tf | Filter time constant for speed error (s) |
Tg | Gate servo time constant (s) |
VELM | Gate velocity limit (pu/s) |
Gmax | Maximum gate opening (pu) |
Gmin | Minimum gate opening (pu) |
Tw | Water starting time (s) |
At | Turbine gain (pu power / pu flow) |
Dturb | Turbine damping factor |
Qnl | No-load water flow (pu) |
Internal parameter: Po = (P / At) + Qnl (initial gate setpoint from load-flow)
Usage Example
Section titled “Usage Example”Show the data record
SYNC_MACH g1 g1 # FP FQ P Q: share of the power-flow injection (FP, FQ) or initial power (P in MW, Q in Mvar) 1. 1. 0. 0. # SNOM: Nominal apparent power, used as base power in the machine model (MVA) 800. # Pnom: Nominal active power of the turbine, used as base power for the turbine model (MW) 760. # H: Inertia constant (s) 3. # D: Damping coefficient (usually set to zero when the damper windings are modelled) (pu) 0. # IBRATIO: Field current base ratio I_fB^mac/I_fB^exc (see above) (pu) 0.95 # TYPE_MOD: Parameter format keyword: RL or XT (case-insensitive) XT # Xl: Leakage reactance L_l (pu) 0.15 # Xd: d-axis synchronous reactance (pu) 1.1 # X'd: d-axis transient reactance (must be smaller than Xd) (pu) 0.25 # X"d: d-axis subtransient reactance (pu) 0.2 # Xq: q-axis synchronous reactance (pu) 0.7 # X'q: q-axis transient reactance (pu) * # X"q: q-axis subtransient reactance (pu) 0.2 # m: Saturation coefficient (set to 0 to neglect saturation) 0.1 # n: Saturation exponent (ignored when m = 0) 6.0257 # Ra: Armature resistance (pu) 0. # T'do: d-axis open-circuit transient time constant (s) 5.00 # T"do: d-axis open-circuit subtransient time constant (s) 0.05 # T'qo: q-axis open-circuit transient time constant (s) * # T"qo: q-axis open-circuit subtransient time constant (s) 0.1EXC GENERIC1 # IFLIM: OEL field current threshold (pu) 1.8991 # d: OEL timer band, usually negative: timer runs down at rate 1 below IFLIM+d, holds between IFLIM+d and IFLIM (pu) -0.1 # f: OEL timer charging rate offset above IFLIM 0. # S: OEL timer charging rate per unit of field overcurrent (1/pu) 1. # K1: Not used by the code 100. # K2: OEL gain on (if - IFLIM), negative so that the OEL lowers excitation (pu/pu) -1. # L1: OEL timer lower limit and initial value, negative; the OEL acts when the timer exceeds 0 (s) -11 # L2: OEL timer upper limit (s) 10. # G: AVR gain (pu/pu) 70. # TA: AVR lead time constant (s) 10. # TB: AVR lag time constant (s) 20. # TE: Exciter time constant (s) 0.1 # L3: Minimum field voltage (pu) 0. # L4: Maximum field voltage (pu) 4. # SPEEDIN: PSS input weight: 1 = speed, 0 = active power 1 # KPSS: PSS gain, derivative washout KPSS s/(1+sTw); 0 disables PSS (pu s) 75. # Tw: PSS washout time constant (s) 15. # T1: PSS first lead-lag numerator time constant (s) 0.2 # T2: PSS first lead-lag denominator time constant (s) 0.01 # T3: PSS second lead-lag numerator time constant (s) 0.2 # T4: PSS second lead-lag denominator time constant (s) 0.01 # DVMIN: PSS output lower limit (pu) -0.1 # DVMAX: PSS output upper limit (pu) 0.1TOR HYGOV # R: permanent droop (pu) 0.05 # r: temporary droop (pu) 0.30 # Tr: temporary droop reset time (s) 5.00 # Tf: filter time constant (s) 0.05 # Tg: gate servo time constant (s) 0.20 # VELM: gate velocity limit (pu/s) 0.20 # Gmax: maximum gate opening (pu) 1.00 # Gmin: minimum gate opening (pu) 0.0 # Tw: water starting time (s) 1.50 # At: turbine gain (pu) 1.10 # Dturb: turbine damping; RAMSES 3.84 adds +Dturb*(omega-1)*g to the power, so positive is destabilising (pu) 0.0 # Qnl: no-load water flow (pu) 0.05;Tw(water starting time) is the dominant parameter controlling frequency response; typical values are 0.5–2 s.r > Ris required for stable regulation; set –5 .Tris the reset time for transient droop; values of 5–30 s are typical.- Non-linear head-flow equation makes this model suitable for large transients.
- Parameters are listed in order:
R r Tr Tf Tg VELM Gmax Gmin Tw At Dturb Qnl.